Team Status Report for 2/21/26

The most significant risk that could jeopardize the success of the project is still the motion sensor since we have still been struggling to find one that would work for our intended purpose. However, this risk has been managed since we were able to find an old mouse lying around and break that apart to take the motion sensor from it. So we will spend time testing that to make sure it works for our intended purpose. If not our only backup so far is to try to get the IMU to effectively track linear motion which has not provided the best results so far since it does not work very well on small movements. Further testing of this will be done just in case.

The only thing that’s changed with our design this week is that instead of building a conversion module from the ground up, we found a Python library called pygame that interfaces with our computer OS to do 1-to-1 CPI-pixel mapping. We will be using this library for the base of our stylus data interfacing after BLE communication. We also may need to change our design depending on which motion sensor we end up choosing. The reason for this is the one we originally wanted is too hard to find and we are still testing the current one we found.  The good thing is all of the motion sensors work relatively the same with slightly different resolutions so the cost for switching is lower resolution but that should not be too much of a problem since we were planning on working on the lowest resolution anyway to start. Overall we can still make it work with mostly any mouse motion sensor we find.

Here is the updated schedule: 18-500 Gantt chart – Gantt Chart

Tsairus’s Status Reports for 2/21/26

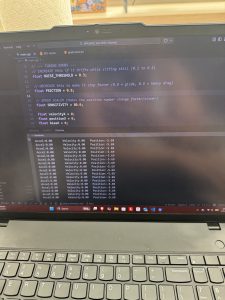
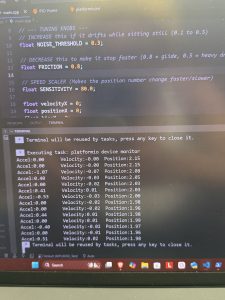
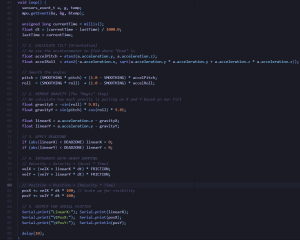
This week I spent more time testing the IMU implementation to see how well the IMU will work in our product. I also tried testing again how well the IMU could detect linear movement and implemented the code in a slightly different way since before I was trying to track the IMU on the surface but then realized the IMU would actually be in the air inside the pen shaft which changes the implementation. The IMU work slightly better when in the air but still does not work the best on small movements. Additional testing and algorithms will need to be done. Here is the main body of the code for that:

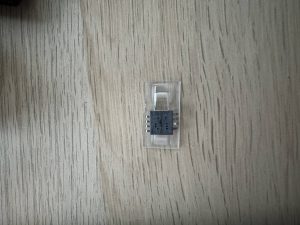
My progress did fall behind a little since I was still struggling to find the mouse sensor and I did not want to start the PCB until I knew the exact part we will use. However, Christian did manage to find an old mouse lying around and I was able to spend some time this week breaking it open and unsolder the mouse sensor from it.

My plans for next week is to test this mouse sensor to see how well it is able to track the surface and send that data to the computer. Also some time at the end of next week I should be able to receive a datasheet from the vender in addition to a quote to buy the sensor if it fits our needs and start working on the PCB schematic/layout. So deliverables is to test the mouse sensor and hopefully finalize the motion sensor we want to use.

Team Status Report for 2/14/26

The most significant risks is obtaining a sensor that can effectively track motion across a surface. We are still thinking of using an optical mouse sensor for our pen to track the surface but we have been having a hard time finding vendors that sell them. Our team is currently talking to a vendor that sells them and we are waiting for a response from them to receive a datasheet to see if what they have will work for us. These risks are being managed by looking into multiple different types of motion sensors to see which ones are available and would work best for our product. One contingency plan we have currently is to try an use the IMU we have in order to track motion across the surface but we will have to sacrifice some accuracy if we decide to go with this plan. We have also found some other motion sensors through vendors like Amazon and Tindie but they are a little bigger than ideal and after reading datasheets we would have to test them first to see if they are worth using in our product.

At the moment, we do not have any changes to our design but if we are unable to obtain our original motion sensor then we could possibly have some design changes in the future.

We slightly updated our schedule to push PCB stuff back by a couple of days: 18-500 Gantt chart – Gantt Chart


Week-Specific Items

A was written by T’sairus Beasley, B was written by Christian Cherry, and C was written by Jamari Toussaint.

Part A (Health, Safety, Welfare):  For welfare, the project is designed to be an easily accessible and essential digital tool that breaks down the current economic barriers that restrict digital literacy and prevent people from having access to convenient technology. Since we were able to engineer a device that works on any surface at a very low-cost (<$50) compared to other expensive options out there, we are able to support the welfare of under-resourced young professionals and artists by providing affordable access to an industry-standard digital tool that will help them in their day to day life. Furthermore, for safety we ensure that the physical design of our product prioritizes user safety through a fully enclosed, non-toxic 3D-printed case that secures the LiPo battery and other electrical components away from harmful encounters to make the device safe for daily use in many environments. For health, our product will maintain a lightweight structure (~25 grams) and will have the weight balanced throughout the entire pen. This will ensure that users will be comfortable with the product and not have to strain their hands or arms through daily use of our product causing unnecessary health problems

Part B (Social Factors): Just as tablet artist and tablet student notetakers became distinctive within the population of artists and students respectively, our Versatile Stylus has the potential to create another group of people who are marked by using our product with their computers rather than a laptop. This can generate a social group of people who dynamically collaborate with each other with larger screens. In addition, it will bring those who cannot afford a tablet into the realm of being able to draw or write digitally. We do recognize the possibility that, since our product is meant to be affordable, this social group may become isolated from those who see having a tablet paired with their stylus as a more premium option or status. On the other side of the coin, given further development time and a wider range of compatibility and features beyond our MVP, our product could replace the specific stylus-tablet dependence of certain tablet products, integrating the tablet and computer social groups with usability that benefits both communities.

Part C (Economic Factors): Considering economic factors, we are looking to design the versatile stylus with robust performance whilst increasing the affordability compared to a usual pen/tablet combo. Our microcontroller and components are relatively available, the only exception being our camera motion sensor. This would require some additional considerations when thinking about moving our product to larger scales. Our communication (bluetooth) is widely used and available for integration with scaffolding available online. Finally, we are looking into using a reusable battery within our design so users will not spend additional costs on upkeep for switching dead batteries. As our stylus is looking to be accessible, we want to include accessible parts for simple use and easy maintenance.
Tsairus’s Status Reports for 2/14/26

This week I decided to look into the PCB Schematic and look more into the motion sensor trying to find vendors that sell them. Originally I wanted to have the PCB schematic and layout done but I first need to find a vendor for the motion sensor we want before I can finish doing this. I am currently speaking with a vendor to arrange a part order for a particular motion sensor. So instead of sitting around waiting for that I decided to also test the IMU functionality to see if it would be possible to implement our entire pen’s motion just with the IMU. After testing, the IMU did not work that well at detecting position as we would have hoped so we are thinking of sticking to our original design of using an optical motion sensor. Here is some photos of the IMU temporarily being setup and tested using an STM32 board until we get our XIAO MCU:

:

My progress is a little behind since I was hoping to have the PCB stuff done and ready to order by the end of this week. The actions I plan on taking to catch up is continue talking to the vendor I am hoping to buy from and get the datasheet from them so that way I can start building the schematic and laying everything out by the next status report. By next week, I hope to finally have the motion sensor decided and ready to order. In addition, I am hoping to have the PCB schematic and layout for the motion sensor completed as well.

Team Status Report for 2/7/26

The most significant risk at the moment is trying to find a motion sensor for our pen. We have been searching for vendors online but have been struggling to buy and find the one that we had originally wanted. We are talking to our TA and faculty member to hopefully find trustworthy vendors to search for the needed part. The contingency plans is we have backup sensors that we could try to look for in order to replace the current one if we cannot find it. We will find backup vendors for other sensors just in case.

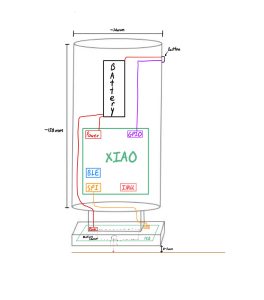
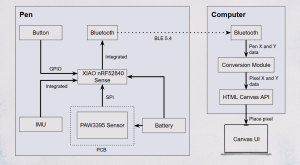
There have not been any changes to our design of the system since the proposal presentation on Wednesday. Here is our current design we are thinking of implementing:

This week we have spent time searching for all of our components plus vendors to buy those components from and compiled them all into a spreadsheet: Components – Sheet1

We updated our schedule dates a little bit to account for the time it took to design our slides for the proposal presentation and look for parts for the design so we are pushing back the PCB and CAD design by a week. Here is the updated schedule: 18-500 Gantt chart – Gantt Chart

Tsairus’s Status Report for 2/7/26

This week I managed to come up with a diagram to properly show how all of the components in our product comes together and draw out a visual representation of what I think the pen should look like. I also took the time to take measurements of the components to help figure out the dimensions that the pen should be and looked into the specs of the motion sensor to make sure it could accomplish the tasks we need from it. In addition to this I spent time coming up with technical challenges and some risk mitigation strategies to counteract what we think our technical challenges are.  I think my progress is on schedule since I was able to come up with a reasonable hardware design and pretty much finished looking for the parts we want.

For next week I am hoping to complete the first round of the PCB schematic and layout for the motion sensor so we can send that to the fab and test it soon to make sure there are no errors.