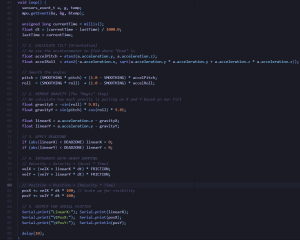
This week I spent more time testing the IMU implementation to see how well the IMU will work in our product. I also tried testing again how well the IMU could detect linear movement and implemented the code in a slightly different way since before I was trying to track the IMU on the surface but then realized the IMU would actually be in the air inside the pen shaft which changes the implementation. The IMU work slightly better when in the air but still does not work the best on small movements. Additional testing and algorithms will need to be done. Here is the main body of the code for that:
My progress did fall behind a little since I was still struggling to find the mouse sensor and I did not want to start the PCB until I knew the exact part we will use. However, Christian did manage to find an old mouse lying around and I was able to spend some time this week breaking it open and unsolder the mouse sensor from it.
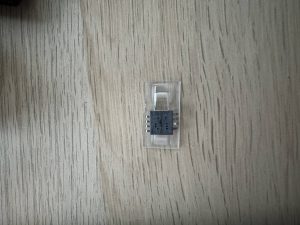
My plans for next week is to test this mouse sensor to see how well it is able to track the surface and send that data to the computer. Also some time at the end of next week I should be able to receive a datasheet from the vender in addition to a quote to buy the sensor if it fits our needs and start working on the PCB schematic/layout. So deliverables is to test the mouse sensor and hopefully finalize the motion sensor we want to use.