
PublicDemo_PosterTemplate_S26.pptx PublicDemo_PosterTemplate_S26
Final Report
Final Video
Team Status Report 04/25
This week, we launched a moored weather balloon in an effort to collect data at night on a moving aerial platform. The test was partially successful, in that we collected data but the feature extraction pipeline broke in the presence of clouds. We are working on post-processing the logs in order to address this.
This week, our focus is primarily on the poster, video, and final report.
Julius Status Report 04/25
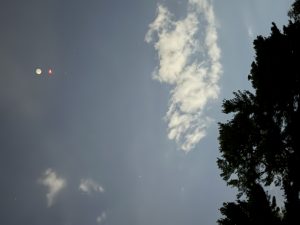
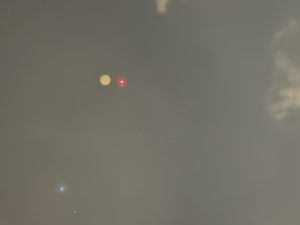
This week, I designed, constructed, and launched a moored weather balloon. I scavenged necessary parts and 3D-printed the gondola, and conducted the flight test at Schenley Park after filing a NOTAM and in accordance with Part 101. The balloon flew successfully, though unfortunately there were issues with power delivery onboard and the Raspberry Pi continued to reboot. More problematic was the weather – though the forecast had forecasted <10% cloud cover, the cloud cover above the test site was above 50%. Useful data was collected, and results demonstrated that feature extraction breaks in the presence of clouds. The balloon ascended to a maximum of 500FT AGL and 1km away. I am working to address this by blurring and thresholding the image to mask out clouds. I will re-evaluate results after this is completed.
Julius Status Report 04/18
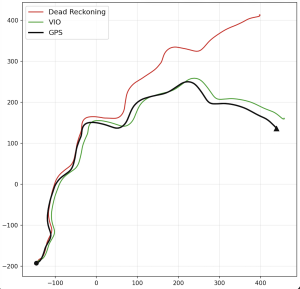
This week, I focused on collecting more data and tuning the estimation pipeline. I mounted the setup atop a vehicle and drove it while collecting data over the course of a 942m long trajectory. I was able to achieve low-frequency attitude rate estimation by cross-matching celestial features found across adjacent camera frames, akin to VIO, which improved trajectory accuracy against GPS ground truth over IMU dead reckoning from >300m to 14m – a large achievement.
I tested celestial global positioning as well and achieved considerable improvements in accuracy, with a median positioning error of 2.1km and p95 at 6.8km.
Team Status Report 04/04
This week, our major progress points were in developing the hardware enclosure for all components and dealing with unforeseen corruption in the Linux install on the Raspberry Pi, which required re-installing the OS and re-configuring the device from scratch. We are in the process of 3D printing the enclosure, and are now set up for data collection this Tuesday when the forecasts show clear skies.
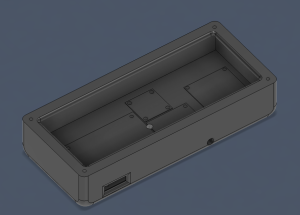
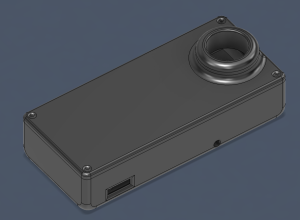
The designs for the enclosure are shown below with and without the top cover:
For validation, we plan to compare our system outputs against known references, including comparing IMU and visual attitude estimates and later comparing position estimates to GPS.
Julius Status Report 04/04
This week, I developed the CAD the hardware enclosure for our components and began 3D printing it. I also set up sensor streaming from the GNSS module, though we identified that our specific module requires an antenna the unit did not come with; we will order it this week.
Our Raspberry Pi Ubuntu installation appears to have become corrupted over the past week, so I invested time in re-flashing and re-configuring it as well.
The enclosure design is shown here with and without the top cover:
Julius Status Report 03/28
This week, the majority of my time was spent on preparing the interim demo. I brought up the camera calibration pipeline for display, and prepared slides on the software stack, calibration processes we developed, and the schedule for the next 3 weeks.
Team Status Report 03/28
This week, the bulk of our preparation went into preparing the interim demo. We conducted further fine tuning of the complimentary filter, and brought up the camera calibration pipeline for demo’ing.
We continue to be blocked by lack of clear skies for testing, though forecasts indicate that this will come in the next 2 weeks.