
This week, our major progress points were in developing the hardware enclosure for all components and dealing with unforeseen corruption in the Linux install on the Raspberry Pi, which required re-installing the OS and re-configuring the device from scratch. We are in the process of 3D printing the enclosure, and are now set up for data collection this Tuesday when the forecasts show clear skies.
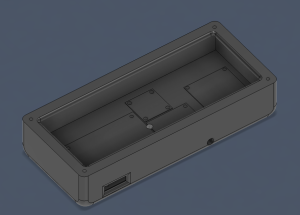
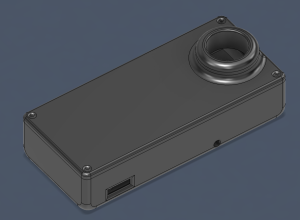
The designs for the enclosure are shown below with and without the top cover:
For validation, we plan to compare our system outputs against known references, including comparing IMU and visual attitude estimates and later comparing position estimates to GPS.