
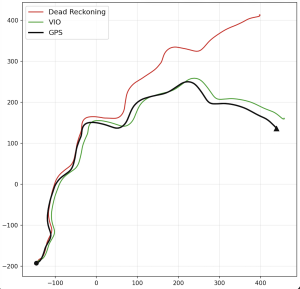
This week, I focused on collecting more data and tuning the estimation pipeline. I mounted the setup atop a vehicle and drove it while collecting data over the course of a 942m long trajectory. I was able to achieve low-frequency attitude rate estimation by cross-matching celestial features found across adjacent camera frames, akin to VIO, which improved trajectory accuracy against GPS ground truth over IMU dead reckoning from >300m to 14m – a large achievement.
I tested celestial global positioning as well and achieved considerable improvements in accuracy, with a median positioning error of 2.1km and p95 at 6.8km.