Christian’s Status Report for 4/4/26

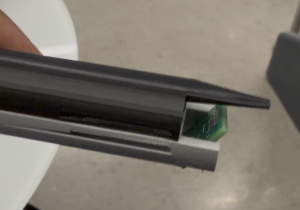
This week I worked on beginning to physically integrate the force sensing resistor and optical sensor into the stylus housing. I extended the end of the stylus housing to include supports for mounting the optical sensor at an angle. For the FSR, I decided the optimal place for it is on the top of the USB-C port on the MCU. My progress is on schedule, and this next week, I plan to have a sliding-push tip mechanism in place for physically pressing the FSR.

For verification, since we have functionality for taking in data from the MCU and displaying writing on our canvas, I will work with Jamari to develop a testbench that measures the latency between when our data is received on the OS to when a line drawing appears on our canvas application. In addition, I will make a testbench that measures the amount of power draw from our lithium ion battery and gives an estimate of how much wireless writing time is left. For the 3D housing, I will weigh it with and without the internal components to verify it meets our requirements.

Tsairus’s Status Reports for 4/4/26

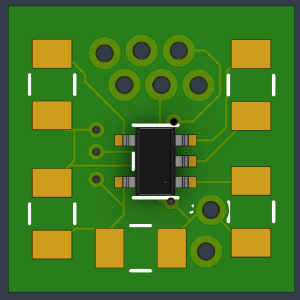
This week I managed to work on the PCB design fixes and submit a new order request for the new updated PCB. Here is the new PCB:
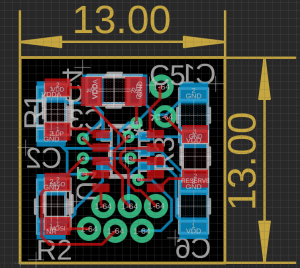
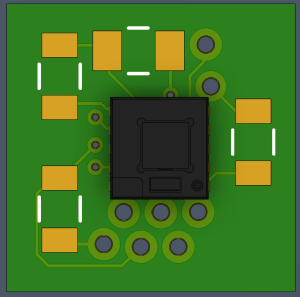
My progress is on schedule and next week I hope to have received the new PCB and solder all of the components onto it. I also want to finish the physical testing of the PCB so that I can focus more on integrating it with the other components.

Week Specific Item

My primary responsibilities are the optical flow PCB, the IMU functionality, and the microcontroller data pipeline. Here are the tests I am thinking about using for verification:

For the optical flow PCB I plan on first doing some physical testing like making sure none of the traces are shorted and all the connections are correct. Then I will run some communication test to ensure the SPI communication is working so I will read the hardcoded product ID of the sensor and make sure the microcontroller receives it correctly.  Finally I will run some accuracy test where I will move the PCB 1 inch on a surface and try this with different CPI settings (400, 800, 1200, etc.) and make sure that the sensor outputs the correct number of counts per inch. For example, at 400 CPI when I move the sensor in the x-direction 1 inch the deltaX value should equal around 400.

For the IMU functionality, one test that I already ran is testing how accurate the IMU tilt is so tilting the IMU 0, 30, 45, and 90 degrees and checking what the IMU output was. The IMU tilt was usually within ~3-5 degrees of the tested angle. Another test I was thinking about running was testing how much the IMU drifts using the current smoothing filter we have so if I leave the IMU stationary on a surface for a few minutes I can record how much the IMU angle fluctuates.

For the microcontroller data pipeline, one test I was planning on doing was inputting hardcoded dummy data and eventually real data into the microcontroller and test how well the dynamic CPI function works. For example at a 60 degree tilt and baseline target CPI of 400 the math should be 400/cos(60) which is a new target CPI of 800 so from that I will verify that the microcontroller correctly sends the correct CPI value to the optical flow sensor. I will also run some latency test to make sure all if this processing happens under the time constraint.
Jamari’s Status Report for 3/28/26

This week, I worked to finalize the bluetooth implementation. With Christian’s help, we found a way to execute code for a general computer to recognize our digital pen as a bluetooth device and connect. This will likely be our permanent communication solution moving forward. Our software has been fixed to clamp the cursor at the edge when the pen goes out of the window, but it is creating some bounding issues that I will look more into.

For next week, I will be helping put together our scripts and materials for our interim demo. After the demo, I will move to setting up testing and validation execution since most of the software is complete. I want to start with setting up timing modules and checking in with Christian to confirm plans for measuring CPI & pen accuracy.

Jamari’s Status Report for 3/21/26

This week, I did some experimenting with bluetooth and helped to finalize the canvasing application. Our implementation currently utilizes built-in functions for tracking mouse events and updating the canvas cursor through changes of the pen location. We also added the draw/move mode functionality on the software side to simulate the use of a button or pressure sensor (through we are waiting to add that to our current housing design).

For the next week, I will be working to finish our bluetooth plan and preparing resources for the interim demo. Once our PCB is ready, we will incorporate it into the physical design, and I can adjust the software side of the code as necessary.