For the week of September 13th – 19th, I primarily focused on researching electrical and embedded-system components required for Iteration 1 of our 6-DOF surface-drawing robot arm. My work centered on identifying suitable power supplies, smart serial bus servo motors, microcontrollers, and supporting drivers. In addition, I investigated object-detection models that could run on the NVIDIA Jetson platform, specifically the YOLOv26 model and the process of training and deploying the model using Google Colab.
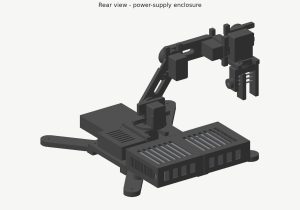
In order to provide adequate power to the NVIDIA Jetson Orin Nano, Intel RealSense Depth Camera D455, 6 smart serial bus servo motors, and possibly a microcontroller, I found that a MeanWell LRS-350-24 24V, 14.6A, 350.4W power supply would be the safest bet, paired with a fuse distributor; it would be easier to have a pair of wires from the power supply to the fuse distributor than to have multiple wires coming straight from the power supply. Given that 24V may be too much for certain components (namely the Jetson), I figured that we would also require a 24V to 12V step-down converter to avoid overcurrent.
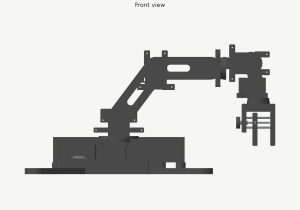
The biggest change from our original concept to the Iteration 1 design was the transition to using smart bus serial servo motors rather than traditional stepper motors. This is because these smart servos provide live position data, which we would have otherwise needed to reverse-engineer using traditional servos. For a project like this that requires exact precision, smart servos would save our group much-needed R&D time that could be used for testing and verification. As we do not yet have accurate simulation data from AutoCAD, we can only estimate our torque requirements. From my preliminary research, I found that Hiwonder, Feetech, and Waveshare offer affordable servos within our budget; I found Robotis Dynamixel servos cost upwards of $100 each, which is unsustainable.
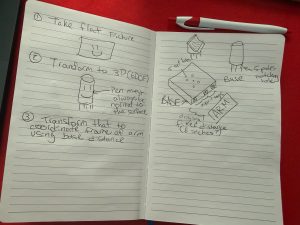
Our team also explored the prospect of using an object detection model to run on the Jetson, for the purpose of identifying different color pens to pick up. Although this is not yet an official requirement, I conducted research into how to implement this. After comparing current commercial object detection models such as SSD, YOLO, DETR, and Faster R-CNN, I established that the only model to combine high accuracy, real-time detection, and compatibility with the Jetson Orin Nano platform was the YOLO family of models. More specifically, there are a variety of YOLOv26 models that are available based on inference speed and GPU strength. Since we do not require many detection classes, the YOLOv26n (nano) model will be sufficient.
Reinforcement learning for the model will be performed on Google Colab, since high-end GPU accelerators are free. To create the dataset, the workflow that Ultralytics provides will be sufficient, since it allows for drawing specific detection polygons onto input images and the simplified creation of different detection classes. As for implementation on the Jetson, I would use OpenCV to grab frames from the camera feed, run the trained YOLOv26n model (exported to a TensorRT-optimized engine file), then output coordinates for the object detection box.
For next week, I aim to complete the following:
- set up Ultralytics workspace
- start training YOLOv26 model on dataset with different color pens
- collaborate with team to finalize design of Iteration 1 and obtain accurate simulation data for servo torque requirements
- assist team to refine master parts list into spreadsheet with prices, links, and any other information
- specifically finalize brands of smart bus serial servo motors