
For this second week, I dedicated my time toward bringing up our robot’s software and hardware stacks, establishing our 3D printing workflow, assisting with mechanical calculations, and preparing for our upcoming design presentation. A major milestone for this week was receiving our embedded computing platform and setting up a functional, local ROS2 development environment directly on the physical hardware (see below).
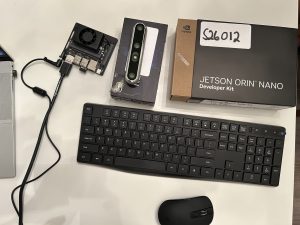
I spent significant time getting the NVIDIA Jetson Orin Nano up and running from scratch. Because the board arrived without an operating system or peripherals, I sourced a DisplayPort cable and a high-speed microSD card for storage, then flashed the Jetson with JetPack 7 Ubuntu. Once the OS was configured, I installed essential command-line tools like tmux and vim alongside ROS2, verifying system stability and environment setups by running the first ROS2 test with 2 publisher and subscriber nodes running simultaneously on the device. Additionally, I helped establish our team’s 3D printing workflow by slicing and executing test prints to evaluate how much time each print will take (photos of these test prints will be on this week’s team report).
Beyond individual setup tasks, I collaborated with the team on refining our master hardware parts list so we can finalize and submit our order for Iteration 1. I also worked alongside the team on CAD Iteration 1, initiating torque and workspace calculations to inform joint placements, limb lengths, and motor specs. Finally, I drafted content for our upcoming design presentation and spent time practicing, as I will be serving as the team’s primary presenter.
I am mostly on track relative to our project roadmap, though we need to make sure the parts list is finalized soon and finish our calculations on torque and workspace in the next few days.
For next week, I plan to:
- Finalize and submit our master hardware parts list for Iteration 1 components.
- Deliver our team’s design presentation and analyze the feedback from faculty and TAs.
- Begin setting up the general software project layout (ROS2) and outline the initial tf2 frame tree structure.
- Finish torque and workspace calculations with the team to finalize motor placements and limb dimensions in CAD.