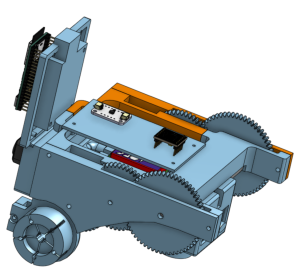
The most significant risk at the moment is that we still do not have a final housing for a robot. As we write this, we have a print in progress for a finalized housing where we’ve worked out all of the remaining issues with the previous rendition which were all related to problems with mounting the breadboard and perf board after having soldered all the necessary connections. The most concerning aspect of this is that we have not been able to test and iterate on any code related to locomotion of the robot.
Since we do not have much time until the final demo, we are attempting to reduce the time we will need to spend working on locomotion by having motor driver code and teleoperation code already written so that we will only have to debug and tune constants once we are able to assemble the housing.
No changes have been made to the block diagram. Regarding schedule changes, the full assembly of the bot has taken longer than previously thought, so all of our testing and final integration will have to take place over this last week.