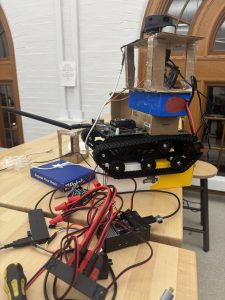
Our current most significant risk is our physical implementation having a cutoff of our camera’s view. It is non-negotiable that our lidar sensor needs to be on top, as if the vehicle obstructs it, any map will be incorrect. Therefore, we need physical supports to hold it up, which will end up obstructing our camera below. Minor camera obstruction is preferable to lidar obstruction because one leads to small blind spots for object recognition, while the other would affect localization and movement. We are currently researching solutions to this problem, with our best idea being that the camera physically moves in a circle around the support of the lidar sensor rather than spinning in place.
We have delayed the speaker integration until we finalize our movement.
Below is our current vehicle with our basic mountings rather than 3d printed ones.