Ran into some obstacles while assembling the newly arrived parts and trying to test the chassis motors:
- the raspberry pis did not come with microSD cards. Thus we can’t yet run any OS on them nor use them to test the robot chassis
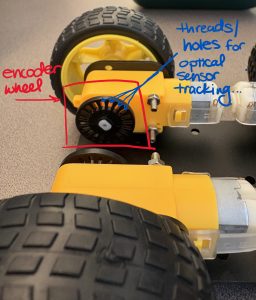
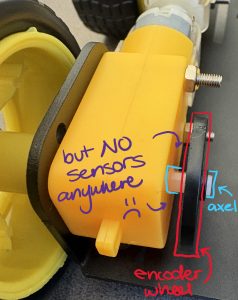
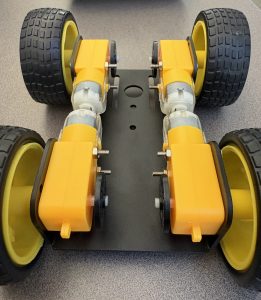
- the chassis kit contains encoder wheels, but no sensors that would return any useful data from the wheels… Thus, even if we could drive the car, we don’t have motor feedback which can be problematic for accurate driving.
Considering these obstacles, this week I accomplished:
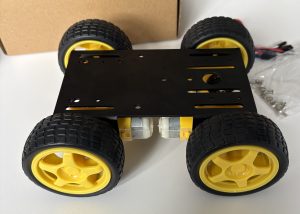
- assembling the first chassis
- ordering microSD cards + adding to the team BOM
- change team Gantt chart to reflect new schedule due to set backs, specifically my task timeline
- created a working doc for my hardware-assembly specific tasks to make it easier to map next-steps in order to prevent set backs from unforeseen obstacles and keep track of my progress
To accomplish next week:
- comprehensive design plan that considers more thoroughly the end-to-end robot in order to prevent similar set backs in the next attempt at reassembly
- evaluate and order new chassis with actual encoder motors!