This week I focused on the SLAM and mapping portion of SWARM, and I also prepared for the design review presentation. I worked on improving the software architecture for the distributed mapping system, and I also investigated how SLAM Toolbox fits into the ROS2-based architecture. SLAM Toolbox is a better fit for this project compared to DOOR-SLAM because it supports LiDAR and ROS2, and it also provides functionality for decentralized multi-robot mapping.
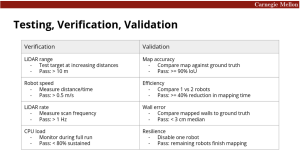
I also worked on defining how we’ll quantitatively test and validate the system. The design requirements are mapped to specific tests, like LiDAR range, scan frequency, robot speed, wall-position error, etc.
My progress is currently on schedule, and the main dependency is receiving and assembling the physical robot hardware. Next week, I plan on working with the team to assemble the physical robot and integrate the SLAM software to begin initial mapping tests.