Team Status Report for 10/10

This week, our team focused on completing the design report, refining the requirements and implementation descriptions, and generating graphs and figures to explain the architecture and prototype. This helped align our hardware, firmware, and desktop application plans.

Our main risks remain reliable posture measurements and hardware integration. Sensor placement and movement could affect accuracy, so we will evaluate mounting stability, calibration, and filtering through repeated testing. We will also test communication with the IMUs and check whether motor vibration disrupts readings. If communication becomes unreliable, we can reduce the I2C bus speed or revise the wiring. The existing breakout-board prototype will allow testing to continue if PCB fabrication or debugging causes delays.

We clarified that posture is measured as regional angular deviation from a personalized baseline. We also documented the choice of one lower-back haptic motor instead of three localized motors, reducing wiring and component complexity. Although vibration will not identify the affected region, the desktop interface can provide that information.

Our overall schedule remains unchanged.

Section A: Rohaib

PosturePal addresses the need for posture awareness during prolonged seated work, a need that extends beyond students in Pittsburgh to people working in offices, studying, or using computers at home. These users may have different body proportions, preferred sitting positions, and levels of technical experience. The adjustable vest and personalized calibration are intended to accommodate these differences rather than assume one fixed posture is suitable for everyone. Configurable thresholds also allow users to choose how much deviation should trigger a reminder. To support users who are less technologically familiar, the interface should provide straightforward calibration instructions and clearly explain what each setting controls. Haptic feedback makes reminders available without requiring users to continuously watch a screen.

Section B: Carys

Different communities and workplaces have different expectations regarding clothing, personal comfort, and the use of wearable devices. PosturePal’s vest must be something users would feel comfortable wearing in their daily environment. Adjustable straps and a as-small-as-possible electronics assembly are used to make the device easier to incorporate into everyday clothing. The haptic reminders also provide a discreet form of feedback that can be used in offices, classrooms, or libraries without creating an audible interruption; instead, it is felt through a buzz. Also, because definitions about “good posture” can vary, the system uses a user-selected reference posture and provides feedback about changes from that reference. This approach gives users control over their settings and avoids presenting one posture as a universal standard.

Section C: Allison

PosturePal’s environmental considerations include battery use, electronic waste, and the materials needed to construct the wearable. The rechargeable lithium-polymer battery supports repeated use without requiring frequent replacement of disposable batteries. However, the battery and other electronic components will eventually require appropriate disposal or recycling. Keeping the electronics removable from the vest would make it easier to repair individual components and separate the textile and electronic portions at the end of their useful lives. Our decision to use a single haptic motor and driver also reduces the number of components and associated wiring compared with a three-motor design. During PCB development, reviewing the schematic and routing before fabrication will help reduce avoidable board revisions and material waste.
Allison’s Status Report for 10/10

This week, I primarily worked on the PosturePal design report and generated graphs and figures to support the explanations of our system. I revised the hardware architecture and implementation sections to describe how the IMUs, I2C multiplexer, microcontroller, and haptic driver connect and work together. I also helped clarify how the system measures regional posture changes relative to a calibrated baseline and how our design requirements will be evaluated during testing. A significant portion of this work involved making the report understandable to someone unfamiliar with the project, including explaining our component choices and the tradeoffs behind them. I worked on organizing the report in LaTeX, formatting equations and figures, and reviewing the text for consistency between the requirements, implementation, and validation sections. The updated design report and accompanying graphs and figures document this week’s progress.

Overall, I think our progress is on schedule. This week was focused heavily on completing the design report, so most of my work involved documenting and refining our design rather than advancing the physical hardware. Writing the report also helped identify details that need to be checked before finalizing the PCB, particularly the connections between the sensing, power, and haptic subsystems. My next priority is to translate those design decisions into the board layout and keep hardware development moving forward over break.

Over break, I plan to work on routing the PCB. I will first review the schematic and component placement, then route the power and signal connections while accounting for connector access, cable organization, and how the board will fit into the wearable. I also plan to check the layout for routing errors and review the connections against our prototype before preparing it for fabrication. My goal is to have a routed PCB ready for team review so that we can address any remaining issues before ordering the board.

Allison’s Status Report for 10/3

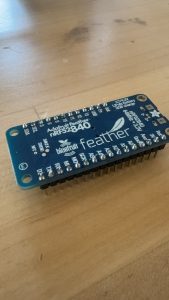
This week, our team finished our design presentation, and I worked on several of the slides, including hardware diagrams and component research that helped us finalize our prototype design. Our ordered parts also arrived on Wednesday, so Carys and I began physically prototyping the system. While Carys worked on the vest design and we discussed ways to securely position the IMUs, I soldered header pins onto several of our components, including the nRF52840 MCU and motor controller, and soldered leads onto the vibration motor. Soldering the MCU was a little nerve-wracking because I initially had the iron set too high and left a small scorch mark near some of the traces. Since we only have one MCU, damaging it could have significantly delayed our progress, but fortunately the board still worked properly. I then wrote a basic program in the Arduino IDE and successfully tested the nRF52840 with the motor controller, making the vibration motor buzz every two seconds. The motor was much smaller than I expected (around half the size of a penny) so I also experimented with how noticeable the vibration would be when worn. I found that applying some pressure against the motor makes the vibration easier to feel, which is something we will need to account for in the vest design. I am also considering whether using multiple motors could improve the feedback, although we would first need to check the additional power requirements and motor driver limitations.

Overall, I think our progress is on schedule. We have moved from component selection and design into physical prototyping, although we still need to verify that the complete sensor system works together as expected. Next week (Monday), our main goal is to assemble an initial E2E prototype for the design report. Once the vest arrives, we can begin testing component placement, but in the meantime we can wire the nRF52840 to the IMUs and begin collecting accelerometer and gyroscope data. We also plan to start developing the MCU firmware for sampling and processing the IMU data so that we can begin reconstructing the relative orientation of the sensors and eventually use that information to estimate posture. These initial experiments should also give us concrete data and results to incorporate into our design report. Additionally, I hope this prototyping gives me the confirmation I need to begin working on the PCB board. Hopefully if I order it by fall break, it can arrive in time.

Here is a picture of the nRF with the pins soldered on (from the back). It was fun, I hope I can do some more!

Allison’s Status Report for 9/26

This week, I focused on finalizing the hardware design for our design presentation and preparing for prototyping. After identifying the components we wanted to use last week, I researched manufacturer and distributor pages to compare availability, shipping times, and specifications. I prioritized parts that could arrive quickly so we can hopefully prototype before the design report is due. This would let us collect preliminary IMU data for our posture calculations while also testing factors such as communication latency and power consumption. I also found breakout-board versions of our components to make initial prototyping easier.

I also researched how these components would translate to our eventual custom PCB. Since we will likely use SMD versions of components such as the IMUs, I checked their availability to avoid potential lead-time issues and found PCB fabrication options as well along the way. Reading through the component documentation also helped me understand their wiring and interface requirements. For example, while considering I2C versus SPI, I realized that I can include jumper or solder pads on the PCB to keep configuration options open rather than committing to one design immediately.

I believe my progress is currently on schedule. Next week, I hope to meet with my team to verify that the complete hardware design works together and begin testing the breakout boards once our components arrive. My main goal is to use what we learn from prototyping to begin the custom PCB schematic, including component connections, power distribution, and configurable interface options, while my team can work in parallel with the breakout board components to begin firmware development.

Below is what our parts list looks like right now. I hope to keep maintaining it like this, maybe adding more columns if necessary, to keep track of our components and budget.

Parts List

Team Status Report for 9/19

As a team, our focus this week was on refining the overarching architecture for PosturePal alongside our respective individual tasks. A shift in our system strategy involved narrowing down our central control unit. While we initially weighed using a Raspberry Pi or an STM32 board, our research demonstrated that a compact, energy-efficient SoC featuring built-in BLE (like the nRF52840) is far better tailored to the wearable’s compute and wireless transmission demands. Beyond the controller, we pinpointed several core trade-offs that require physical validation prior to finalization. These include selecting between I²C and SPI protocols, establishing sensor timestamping methods, and determining if localized multi-point haptics offer sufficient utility to warrant the extra power draw, cabling complexity, and signal noise on the IMUs. Building a preliminary test bench will let us analyze these parameters in a unified setup before ordering our custom boards.

Splitting up hardware, firmware, sensing, mechanical housing, haptics, and app development lets us make concurrent progress, but it leaves our deliverables tightly coupled. Ensuring the full system functions properly means that these distinct parts must interface seamlessly. To mitigate this risk, we plan to prototype interfaces early on and integrate as early as possible. Looking ahead to next week, we plan to first finalize the design review/proposal, and if orders come in, then we would also look to wire the three IMUs onto a physical test rig, gather sample data across various user postures, assess bus communication and experiment with haptic placement to gauge its influence on sensor readings.

Allison’s Status Report for 9/19

My goal this week was to determine the hardware we need for PosturePal and develop a more concrete system architecture. Our main components consist of three IMUs placed at T3, T12, and S1 to measure spinal orientation and movement, and a central controller that will process the sensor data, determine when to trigger haptic feedback, and communicate over Bluetooth with our companion software. We are heavily leaning toward the LSM6DSOX for the IMUs, and I investigated how its support for I²C and SPI, but not wireless communication, affects the rest of our design. Rather than putting a battery and wireless controller at every sensor, we plan to connect the three IMUs by thin wiring to one central hub. I also determined that a Raspberry Pi is likely unnecessarily powerful, large, and power-hungry for our application. Instead, I investigated smaller, lower-power microcontrollers/SoCs with integrated BLE, particularly the nRF52840, while keeping wireless STM32 options under consideration. The nRF52840 appears promising because it can handle our sensor processing and Bluetooth communication on a single device.

From this research, I developed a preliminary design consisting of one custom central PCB and three much smaller, identical sensor PCBs. The central PCB would contain the MCU/SoC, battery and charging circuitry, voltage regulation, sensor interfaces, potentially an I²C multiplexer, and possibly the haptic-driving circuitry. Each sensor PCB would contain an LSM6DSOX and connectors that allow a thin cable to continue along the spine between the hub, S1, T12, and T3. I also investigated several design tradeoffs that we do not want to finalize before prototyping. I²C requires fewer wires and is attractive for a wearable, while SPI avoids some addressing issues but requires more conductors. Both also require us to consider the timing differences between measurements from the three IMUs, so our current plan is to timestamp samples. I also began investigating our haptic feedback design, particularly whether localized feedback at multiple points along the spine provides a meaningful benefit over a single haptic motor. Multiple motors could provide more intuitive feedback about where the user’s posture needs correction, but would add wiring, power consumption, and potential interference with the IMU measurements. We therefore plan to test both localized and centralized haptic feedback before finalizing the design. Overall, I believe my progress is on schedule and this week significantly narrowed our hardware architecture while identifying the remaining decisions that need experimental validation.