Accomplishments
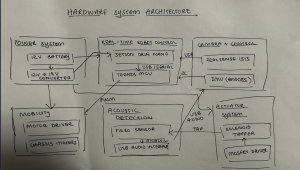
This week, our group had multiple discussions surrounding our implementation plans. From hardware architecture, power requirements, and design requirements, to what our testing should look like. This week, I was primarily responsible for hardware design and focusing on how our Jetson and IMU would work together with the sensors and robot chassis to make sure our project hit the overall MVP goals we set for ourselves. Working with Rayann, I discussed how the hardware would interact with the ML component of our project as well as how our audio would be collected.
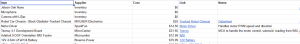
At the start of the week, we were under the impression that we could use an AE sensor which would collect the sound made from our solenoid tapping against the walls of our HVAC duct. As a result, I was tasked with finding a way to approach our acoustic signal capture within the walls of an HVAC duct that we can then use for our audio processing. After researching and finding different solutions, I have settled on using a Behringer UM2 USB Audio interface which can act as the USB audio interface for capturing contact sensor signals. I found that this works with Jetson’s USB to capture analog vibration signals. I also settled on using a basic piezo element diaphragm which will serve as a piezo sensor detecting the taps against the HVAC duct.
This week, I focused mainly on iterating and finalizing hardware systems architecture plans so that our team has a solid understanding of how all of our components will work together. I also have purchased the parts for our team and we expect to receive them next week. I also worked with Mahati and Rayann to finalize testing plans. I also found a civil engineering classmate who is willing to donate some HVAC ducts she got from her internship.
Schedule
I am on schedule now and currently on track. As a team, the goal was to finalize the parts list and research the different components. I also finished my research on power distribution to the Jetson nano as well as the rest of our system. The one thing I hoped to achieve but didn’t get round to was putting together the solenoid tapping mechanism but since we changed our approach, I plan to try and get it done next week when parts start arriving.
Next Week
Next week, I plan to take the parts we receive to build the initial robot chassis and have motor control. I will also put the solenoid tapper together and figure out how to make our robot chassis remote controlled. Before the remote controlled part, we will control the motor movement using our MCU and IMU. I also plan to begin testing simple connections with the solenoid tapper which will help me decide if these parts work well. If parts do not arrive, it is not a big problem as I will be working closely with Mahati on our software development and putting together our HVAC testing system to collect initial audio data.