Accomplishments
This week, I worked very closely with Mahati in the week leading up to our interim demo. We accomplished a series of things.
With Mahati, I worked on fine tuning the motor control of the robot that was already in place and we soldered our final circuit onto a permaboard so that it could be elegantly presented. Currently, the motors move at the set speed according to the specification we set when we initially came up with our design. Then, we moved onto helping Rayann with collecting data from our tranceiver and receiver modules, running it through an ADC, then feeding in the values that were read into the ML model that was built by Rayann and Mahati. We can now run the ML model on our Jetson, and the Jetson controls the Teensy MCU. Mahati and I also worked on integrating the LiDAR with our robot.
On my own, I have also been building the HVAC duct with one 90 degree turn that will be used for our demo. I also took a look at our remaining schedule and how we plan to utilize the time we have before the end of the semester and before our final demo presentations.
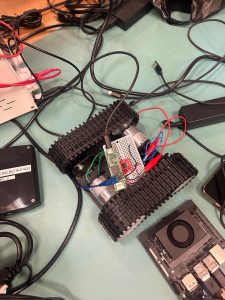
My work this week has mainly been on Github and working on the physical robot itself and can be found here: https://github.com/aphadke234/ece_capstone_C7
Schedule
I am on schedule now and currently on track. The interim demo is this upcoming Monday and as a team, we achieved everything discussed with our Professor and our TA, except for the solenoid tapper, which we have set up but have not had success integrating in time for the interim demo. This will have to be looked at in the coming week, and be addressed immediately.
Next Week
Next week, I plan to prioritize making our robot movements smoother so they don’t damage the duct while moving through them. I also plan to integrate the solenoid driver so that Mahati and Rayann can focus on the ML model. I am still meeting with the HVAC trade school contact we made to figure out how to build the system for our final demo. I have also been going to junkyards with him and will continue to do so once a week until 2 weeks from now, at which point, I think we will have all the training samples we need for our project. I will also aid Mahati with the IMU integration next week.